|
I am a final-year PhD student at Stanford advised by Dorsa Sadigh. I am also a research intern at Amazon FAR (Frontier AI & Robotics). Previously, my research was supported by the NDSEG Fellowship. I was also awarded the NSF Graduate Research Fellowship. I graduated from UC Berkeley with an MS in Computer Science and BA in Computer Science and Applied Math. I was fortunate to be advised by Pieter Abbeel, Stephen James, and Youngwoon Lee at BAIR.
Contact: amberxie@stanford.edu
|
|
|
I'm interested in robot learning. In particular, I would like to build intelligent, adaptable, multi-purpose robots that can learn quickly and accomplish complex tasks. I've worked on a variety of projects in deep reinforcement learning, imitation learning, and generative models to this aim. |
|
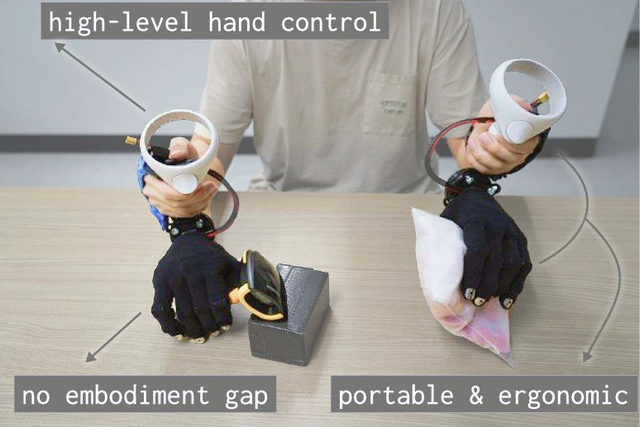
Amber Xie, Jiawei Fu, Xiaofeng Guo, Carmelo Sferrazza, Guanya Shi, Haozhi Qi arXiv preprint, 2026 paper / website DexPort is a portable, hand-held interface for collecting dexterous hand demonstrations. It uses the same hand hardware for collection and deployment, avoiding an embodiment gap, and records the commanded joint targets that policies need to learn forceful grasps. |
|
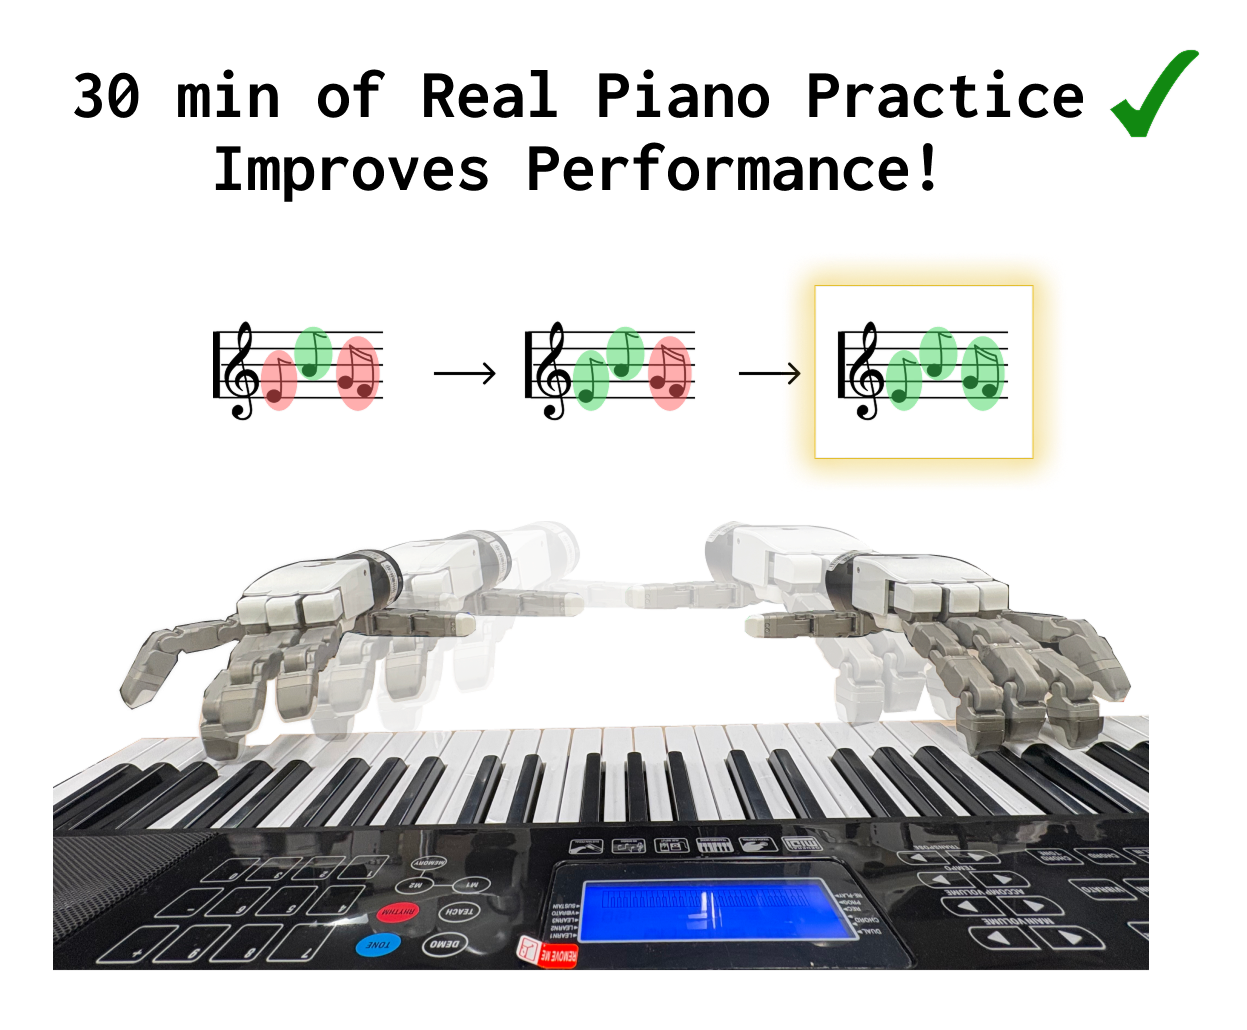
Amber Xie, Haozhi Qi, Dorsa Sadigh Humanoids 2026 International Conference on Humanoid Robots, 2026 paper / website / code Handelbot is the first learning-based system for real-world, two-handed piano playing. We train a simulation policy, and adapt it to the real world using policy refinement and residual RL. |
|
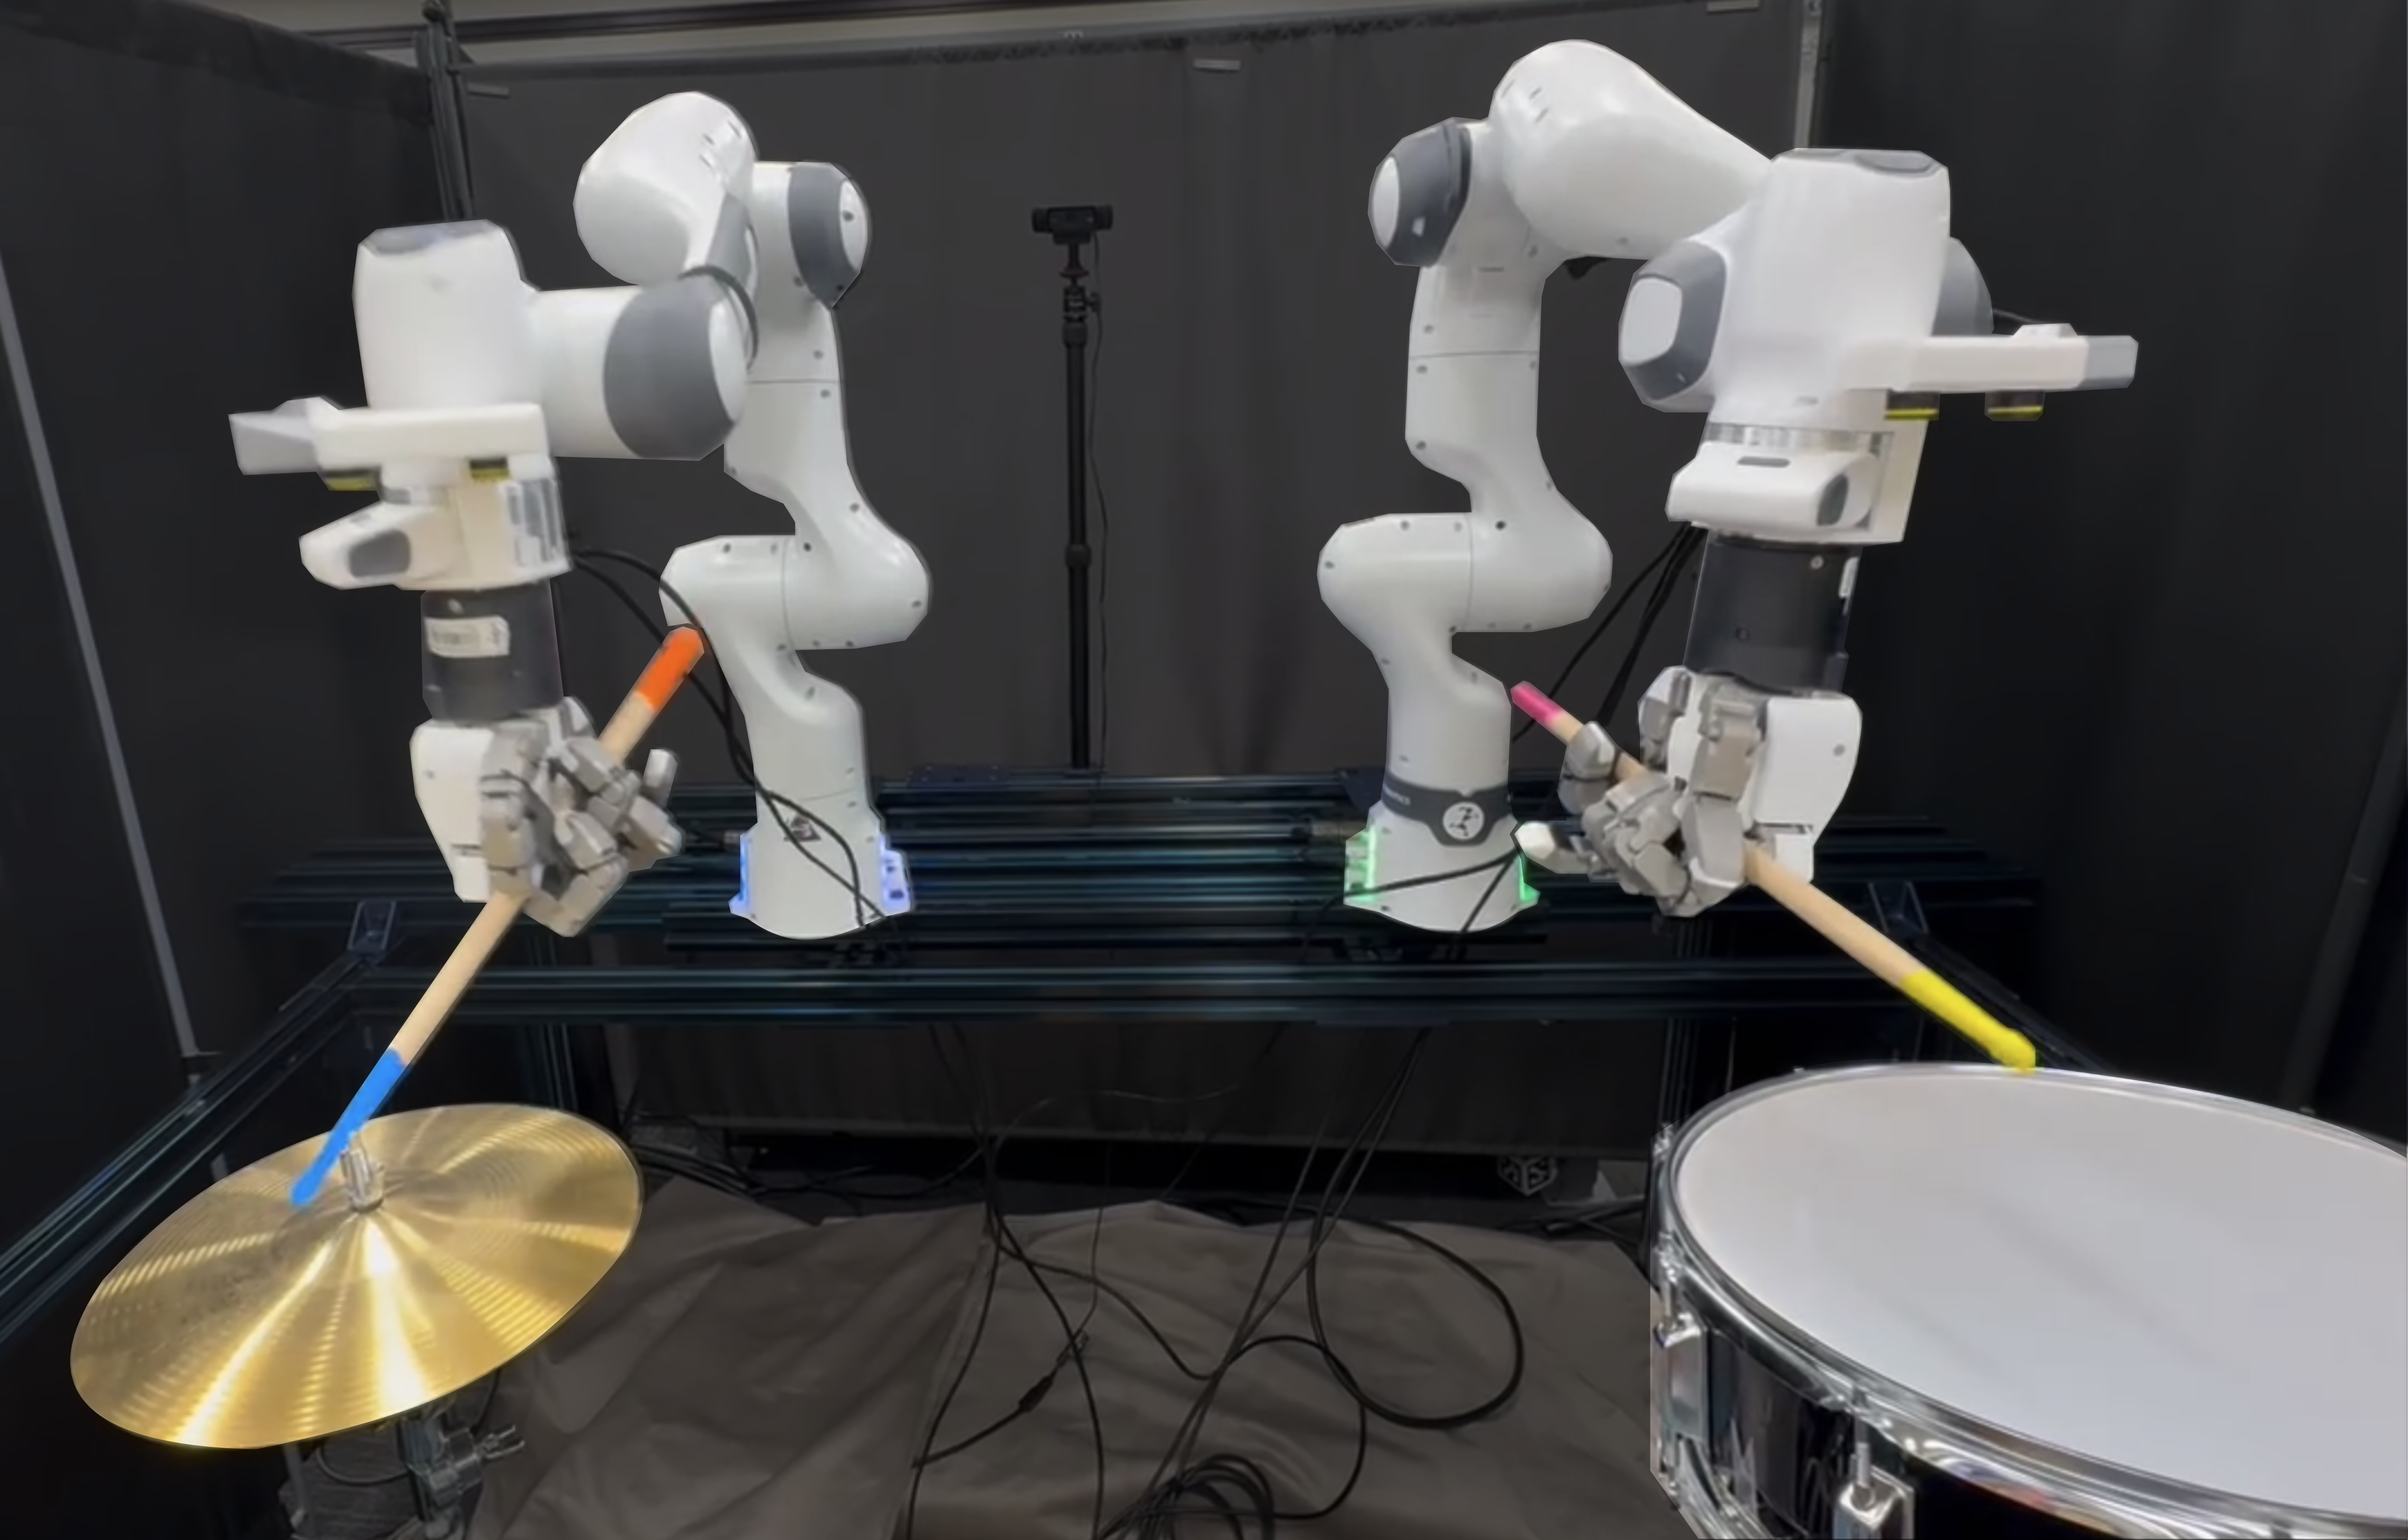
Hung-Chieh Fang, Amber Xie, Jennifer Grannen, Kenneth Llontop, Dorsa Sadigh ICRA 2026 Workshop on Dexterity with Multifingered Hands: Hardware, Sensing, and Skills, 2026 paper / website / code Manipulation often requires dexterous in-hand tool use, complex contact interactions, and stability over long horizons. We propose DexDrummer, a hierarchical sim-to-real framework that integrates these capabilities within a unified drumming testbed. |
|
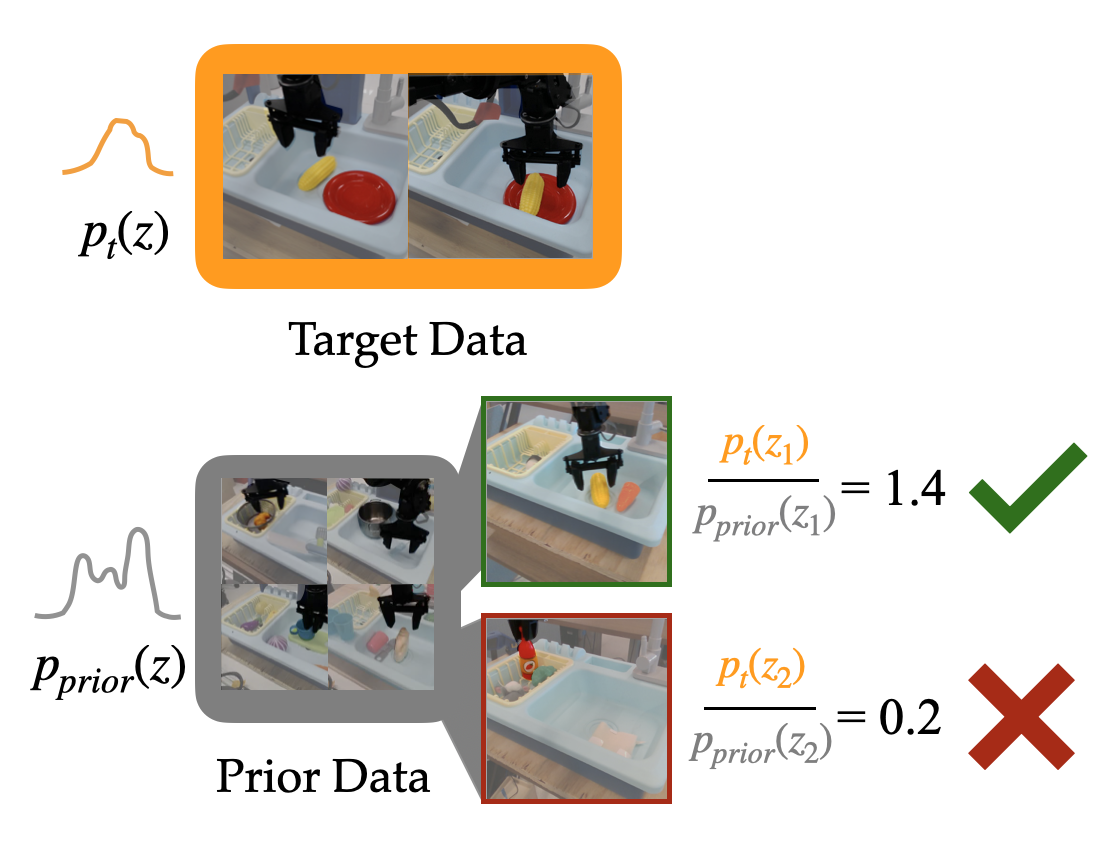
Amber Xie, Rahul Chand, Dorsa Sadigh, Joey Hejna CoRL 2025 Oral Presentation Conference on Robot Learning, 2025 paper / website / code Importance Weighted Retrieval (IWR) is a retrieval method that estimates importance weights, or the ratio between the target and prior data distributions, using Gaussian KDEs. |
|
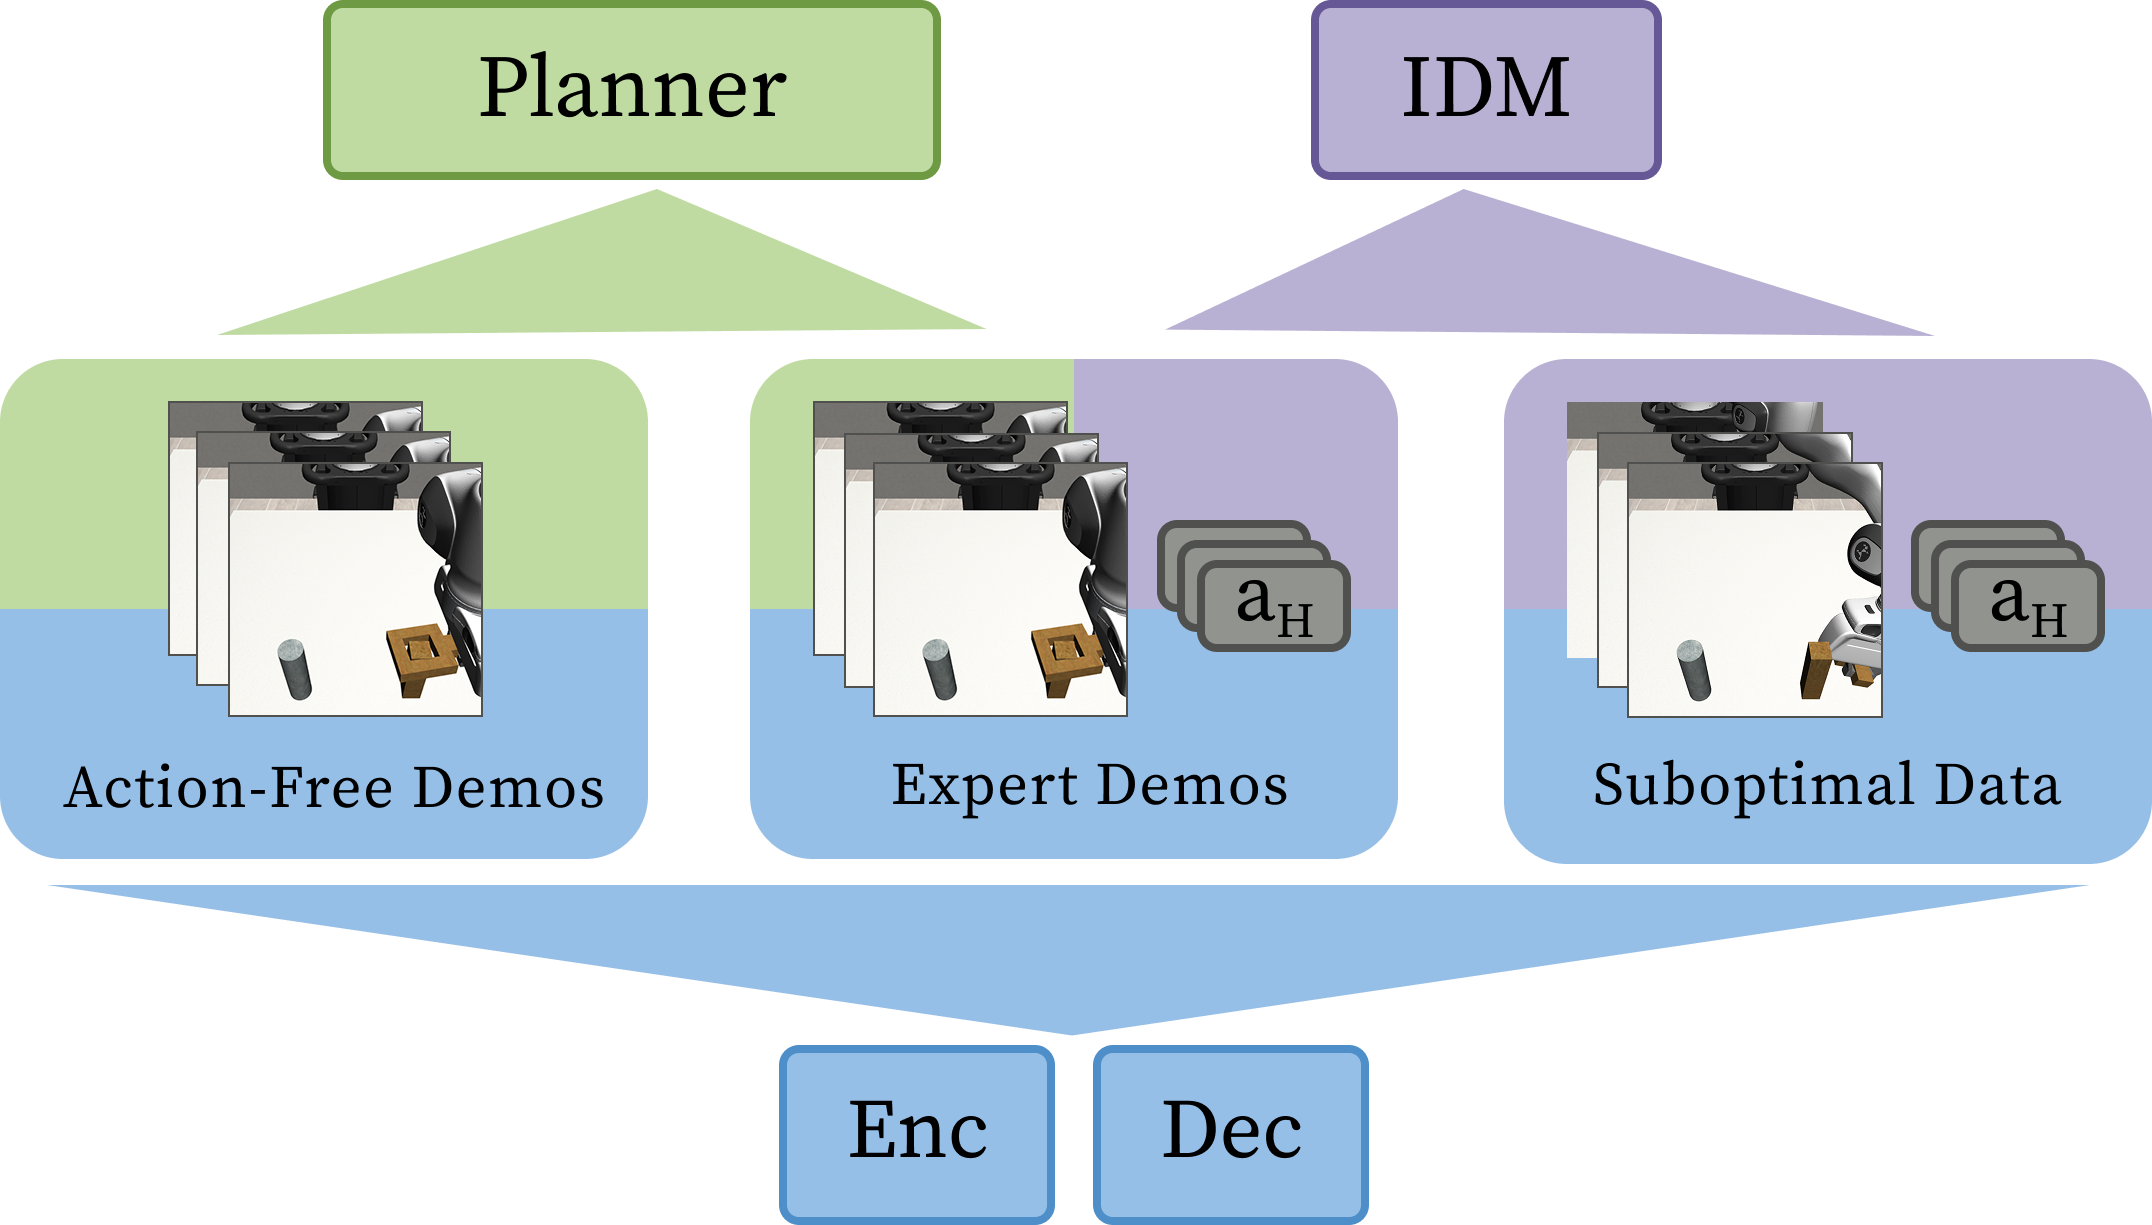
Amber Xie, Oleh Rybkin, Dorsa Sadigh, Chelsea Finn ICML 2025 Spotlight (top 2.6%) International Conference on Machine Learning, 2025 paper / website / code We propose Latent Diffusion Planning (LDP), a modular approach consisting of a planner which can leverage action-free demonstrations, and an inverse dynamics model which can leverage suboptimal data, that both operate over a learned latent space. |
|
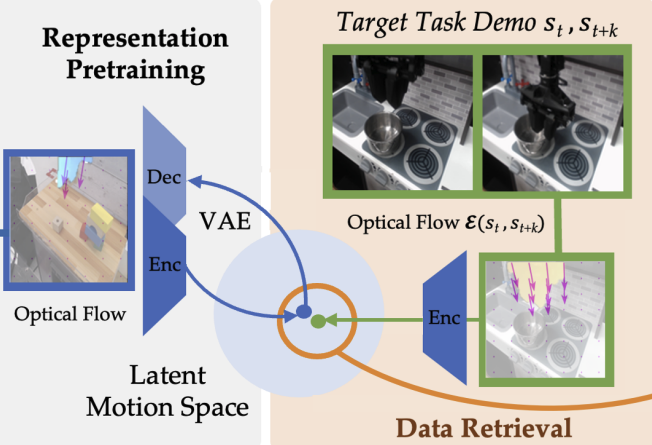
Li-Heng Lin, Yuchen Cui, Amber Xie, Tianyu Hua, Dorsa Sadigh CoRL 2024 Conference on Robot Learning, 2024 paper / website / code FlowRetrieval leverages optical flow representations for extracting relevant prior data and guiding policy learning to maximally benefit from the retrieved data. |
|
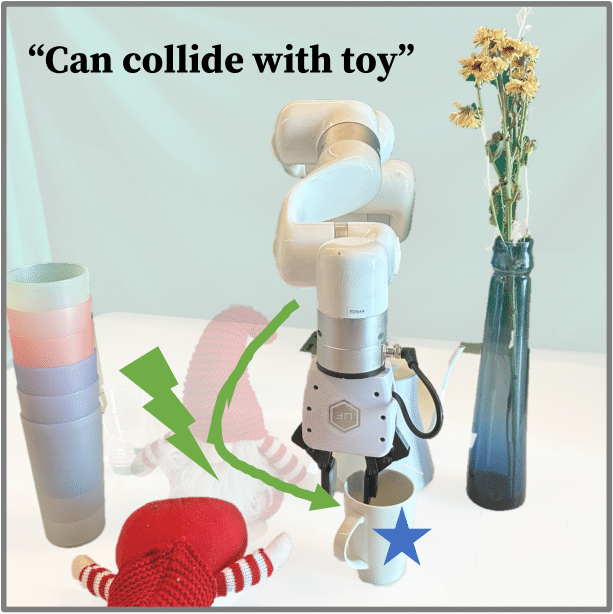
Amber Xie, Youngwoon Lee, Pieter Abbeel, Stephen James CoRL 2023 Conference on Robot Learning, 2023 paper / website / code / video We propose the domain of Language-Conditioned Path Planning (LAPP), where contact-awareness is incorporated into the path planning problem. As a first step, we propose Language-Conditioned Collision Functions (LACO). |
|
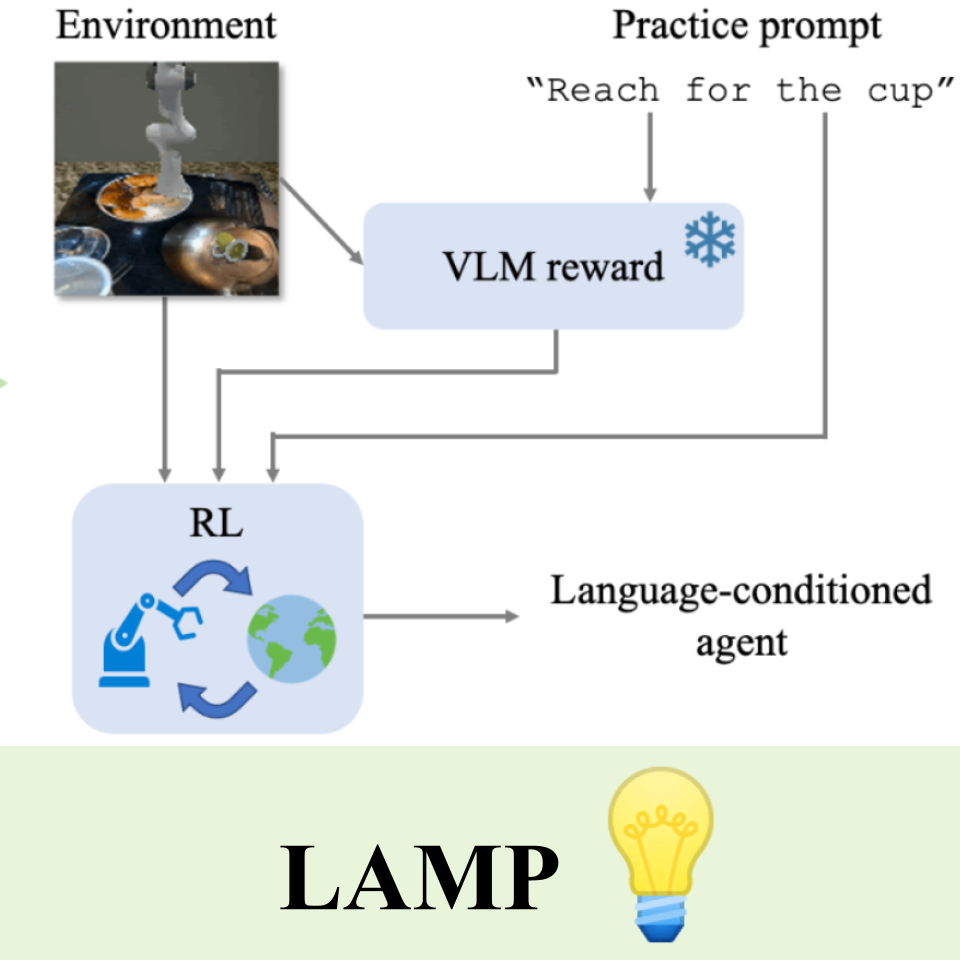
Ademi Adeniji, Amber Xie, Carmelo Sferrazza, Younggyo Seo, Stephen James, Pieter Abbeel RLC Training Agents with Foundation Models Workshop, 2024 paper / code LAMP pretrains a language-conditioned agent without human supervision using noisy VLM rewards and unsupervised reinforcement learning. |
|
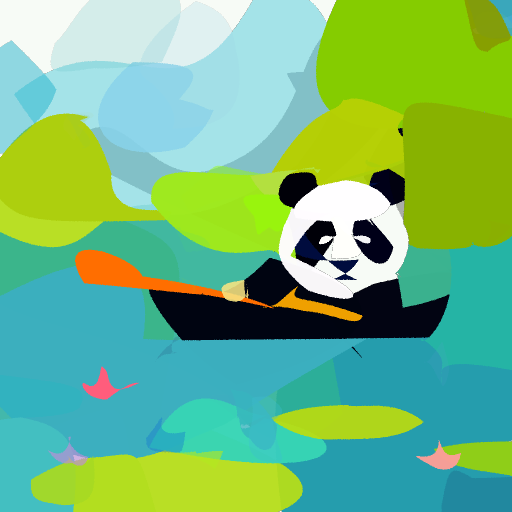
Ajay Jain*, Amber Xie*, Pieter Abbeel CVPR 2023 The IEEE/CVF Conference on Computer Vision and Pattern Recognition, 2023 paper / website / gallery VectorFusion generates infinitely scalable vector graphics (SVGs), pixel art and sketches from text using the pretrained Stable Diffusion model. |
|
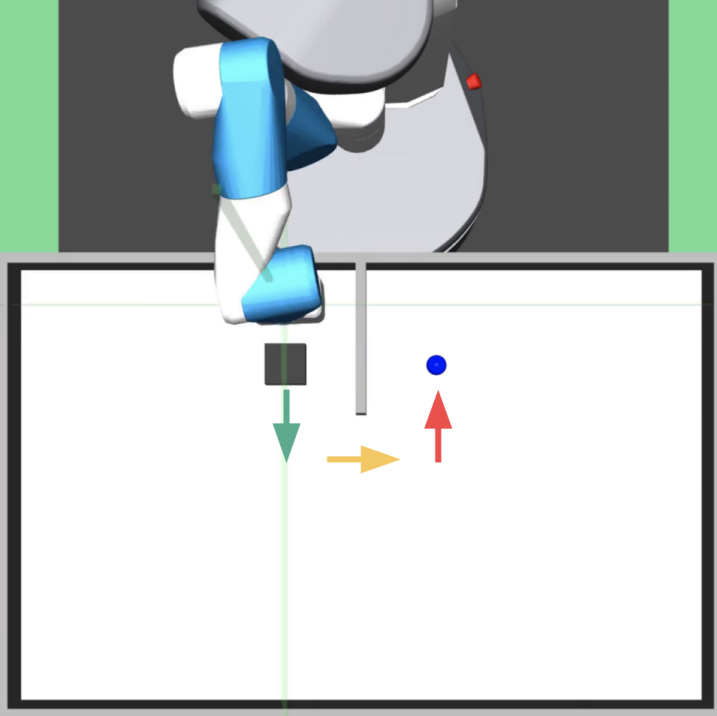
Ademi Adeniji*, Amber Xie*, Pieter Abbeel NeurIPS Intrinsically Motivated Open-ended Learning Workshop, 2023 paper / code IRM leverages the skill discriminator from unsupervised RL pretraining to perform environment-interaction-free skill sequencing for unseen downstream tasks. |
|
John So*, Amber Xie*, Sunggoo Jung, Jeffrey Edlund, Rohan Thakker, Ali-akbar Agha-mohammad, Pieter Abbeel, Stephen James CoRL 2022 Conference on Robot Learning, 2022 paper / website / code / method vid / real-world vid Segmentations are a concise, compressed representation for images. We show sim-to-real transfer through training an RL agent on image segmentations for off-road autonomous driving. |
|
Website template from Jon Barron |